Tahsin Khan

Senior Project Technical Assistant, ERTS Lab (e-Yantra), IIT Bombay

I'm a robotics engineer at the ERTS Lab, IIT Bombay, working on autonomy for ground and aerial robots. I hold a B.Tech in Mechanical Engineering from NITK Surathkal.

My recent work covers grasp-anchored cooperative transport with two mobile manipulators, LiDAR and visual SLAM on UAVs, monocular autonomy for Ackermann vehicles, and remote robotics education platforms. Along the way I have worked on state estimation, motion planning, optimisation-based control and imitation learning for bimanual manipulation.

Portrait of Tahsin Khan

Research interests

Multi-robot systems

Teams of robots that coordinate, share information and work together on tasks no single robot can do alone.

Hybrid model-based and learned autonomy

Pairing model-based estimation and control with learned policies.

Soft robotics and biomimetics

Compliant grippers and mechanisms that relax precision demands on the rest of the robot.

Selected work All research

Video

Ongoing

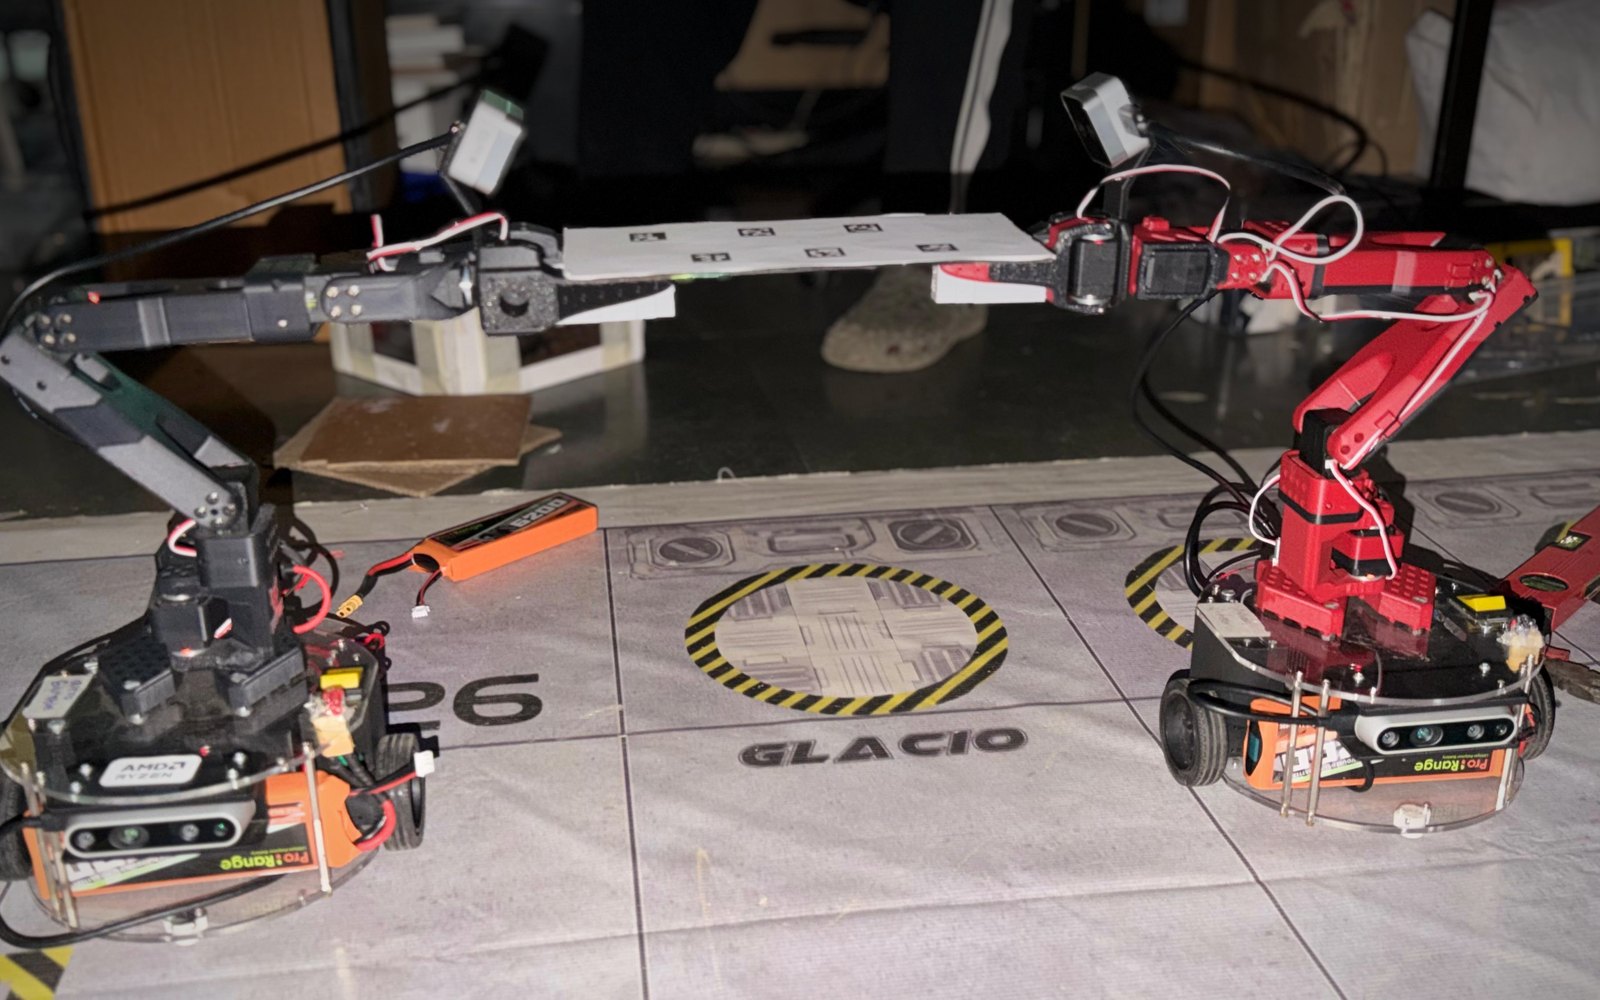
Grasp-Anchored Cooperative Transport

Two custom mobile manipulators carry one payload with onboard vision only: no mocap, no shared map.

  • Posed planning and control in the payload frame, so transport depends only on the relative pose between the two robots.
  • Recovered relative pose through the kinematic chain of the shared grasp, with an EKF on SE(3) running at 50 Hz on a Jetson Orin.
  • Mobile Manipulation
  • Multi-Agent
  • State Estimation
  • Control
Video

Ongoing, paper in preparation

Remote Labs for Robotics Education

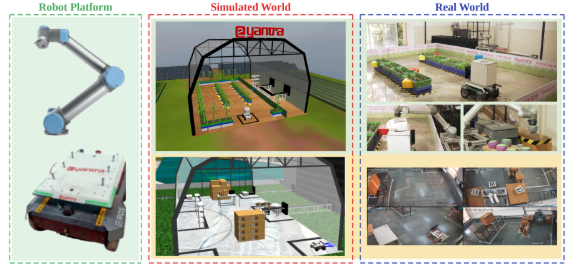
475 hours of remote access to a real UR5 and mobile robot for 649 student teams.

  • Education & Outreach
  • Manipulation

Publications

News

Sep 2026

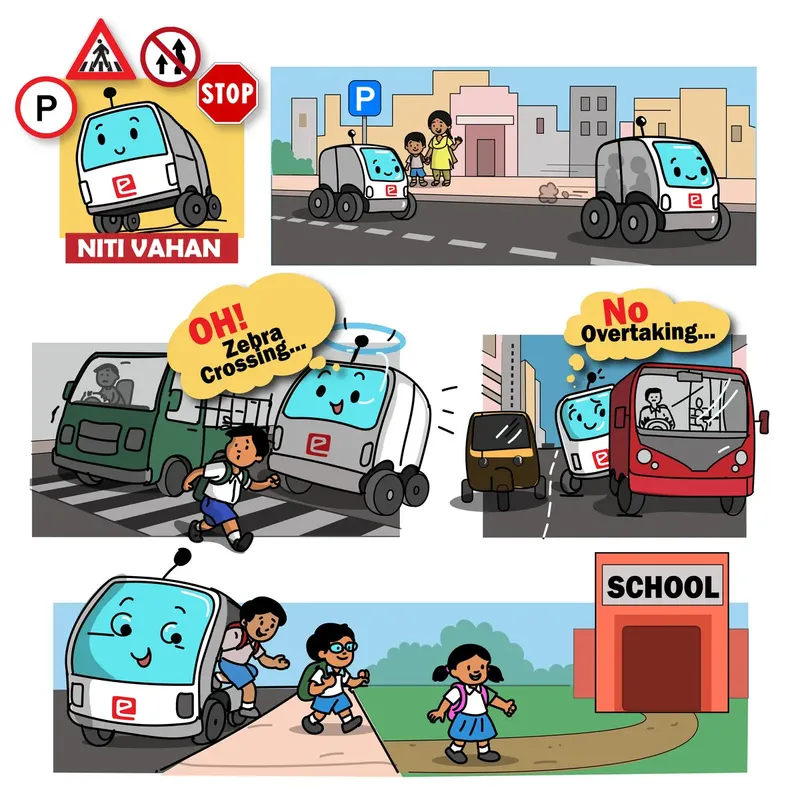
Niti Vahan, the new eYRC 2026-27 theme on autonomous driving, is live and was selected by 1500 teams nationally.

Aug 2026

Gave a beginner-friendly talk on imitation learning and VLAs with LeRobot and the SO-101 arm, for e-Yantra's SO-101 series (watch).

Jul 2026

Mentored three eYSIP 2026 projects: imitation learning on bimanual SO-101 and UR5 arms, and 3D LiDAR SLAM on a Holybro X500.

Mar 2026

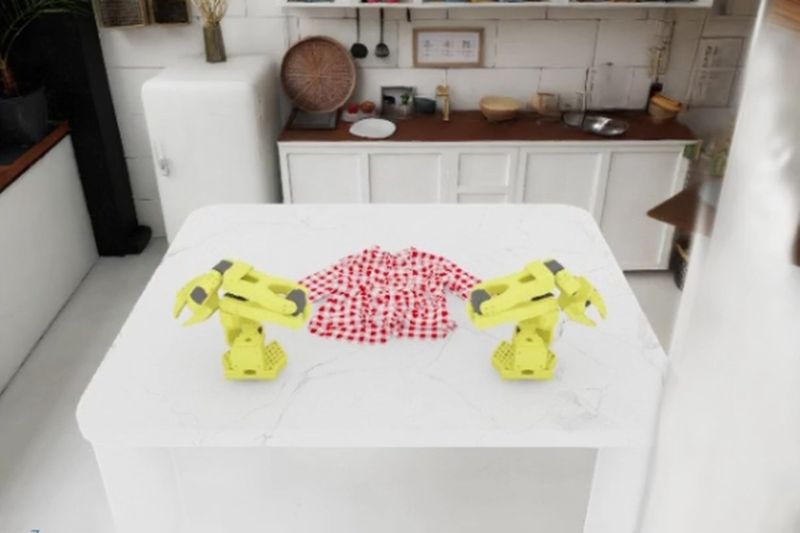
Ranked 32 of 62 teams internationally in the LeHome Challenge at IEEE ICRA 2026, on bimanual cloth folding in Isaac Sim.

Feb 2026

Started research on grasp-anchored cooperative transport with two custom mobile manipulators and onboard vision only.

Jan 2026

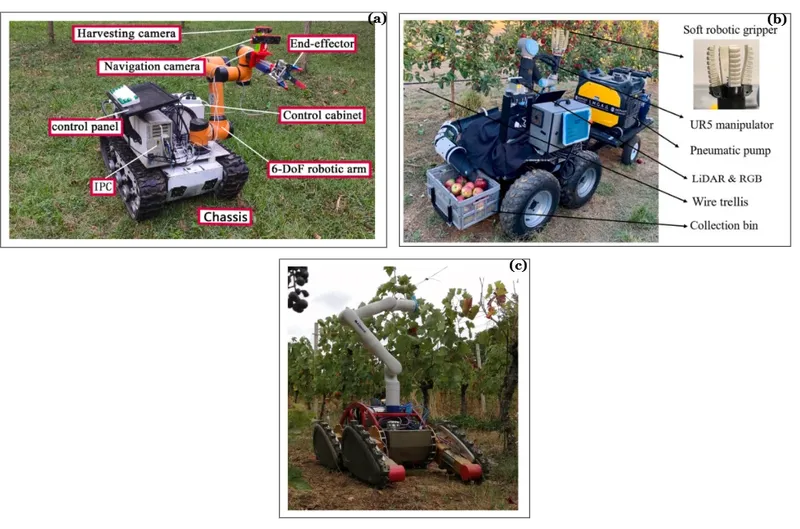
Our review on soft autonomous mobile manipulators in agricultural automation is published in Industrial Robot, Vol. 53 No. 2.

Aug 2025

Joined the ERTS Lab (e-Yantra), IIT Bombay as a Senior Project Technical Assistant.