Industrial Robot 2026, 4 citations
Soft Autonomous Mobile Manipulators in Agricultural Automation: A Review
The first comprehensive review of soft mobile manipulation as an integrated system for agriculture.
- Soft Robotics
- Mobile Manipulation
- Planning
My contributions
- Wrote a systematic review of soft mobile manipulators for agriculture, published in Industrial Robot (2026).
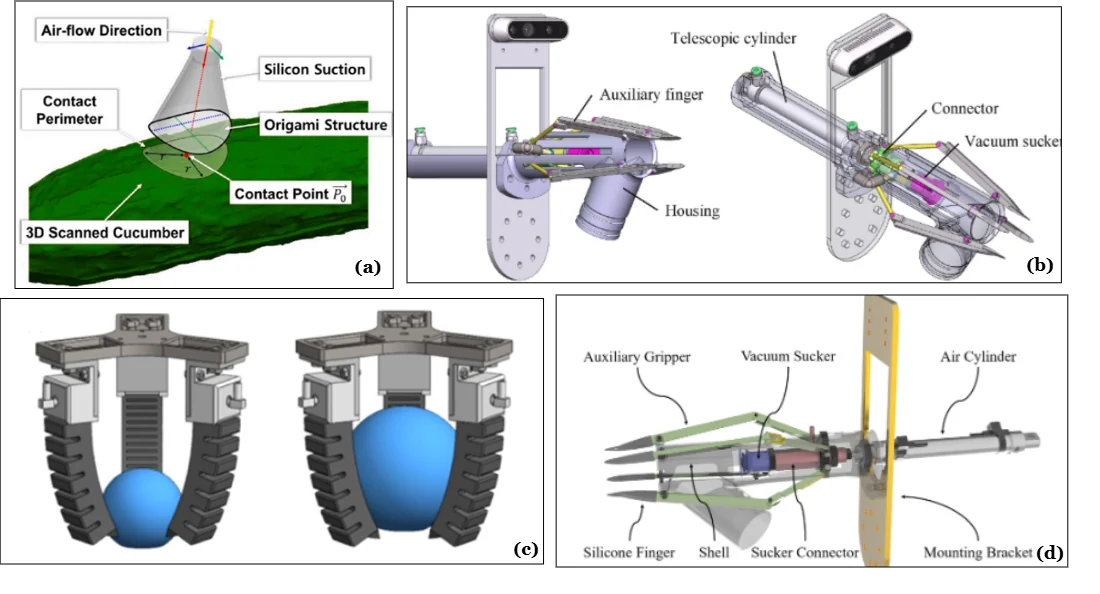
- Compared soft gripping and actuation across actuator families on compliance, payload and crop damage.
- Analysed the mobile manipulator design space to show where gripper compliance relaxes precision on the base and arm.
Published in Industrial Robot, Vol. 53 No. 2, pp. 376-398 (2026). Written with Prof. Mervin Joe Thomas at NITK Surathkal.
Why this review
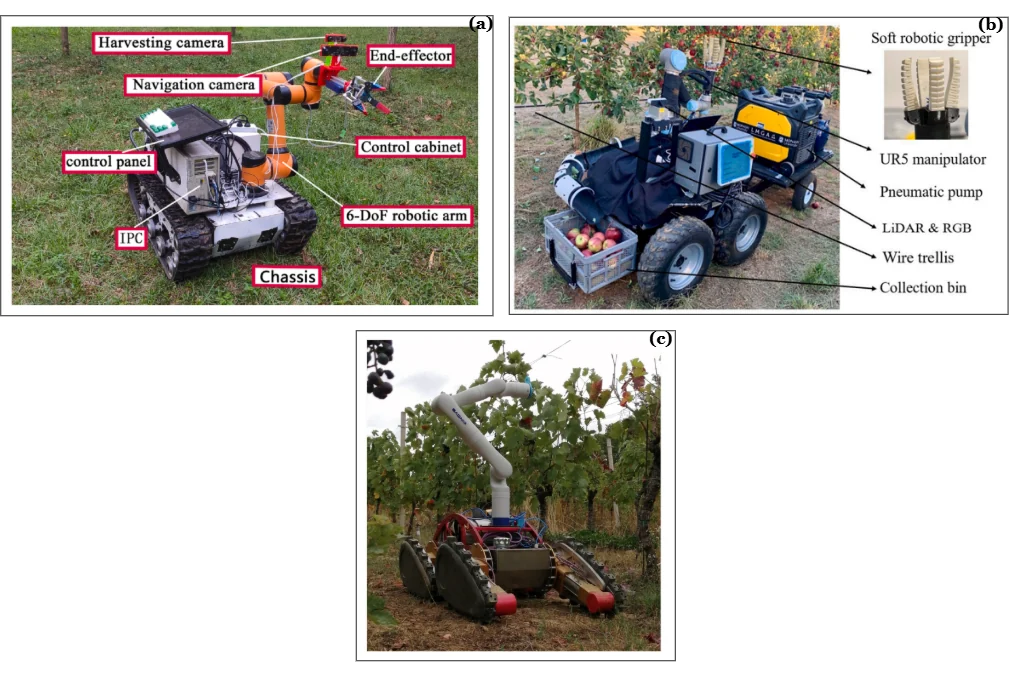
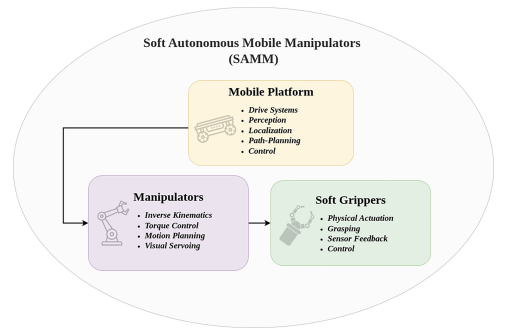
A soft autonomous mobile manipulator combines three parts: a mobile platform, a manipulator arm and a soft gripper. Each has advanced quickly on its own, but no review had examined soft mobile manipulation as one system for agriculture. This paper fills that gap for harvesting and crop monitoring.
What it covers
Soft grippers: gripping and actuation technologies compared across actuator families, assessing compliance, payload and crop-damage trade-offs for harvesting.
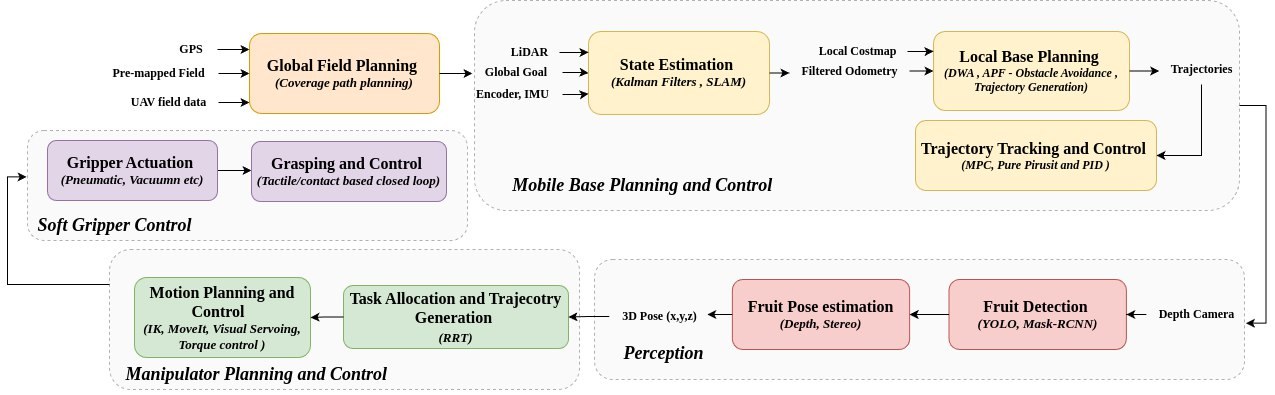
Mobile bases: classical and state-of-the-art localisation and path planning for robots operating in unstructured field environments.
Integration: motion planning for the mobile manipulator as a whole, and an analysis of its design space.
Findings
Integration is the hard part: real-time control, adapting to the field, and coordinating mobility with manipulation. The design-space analysis shows where gripper compliance relaxes the precision required from the base and the arm.
Gallery