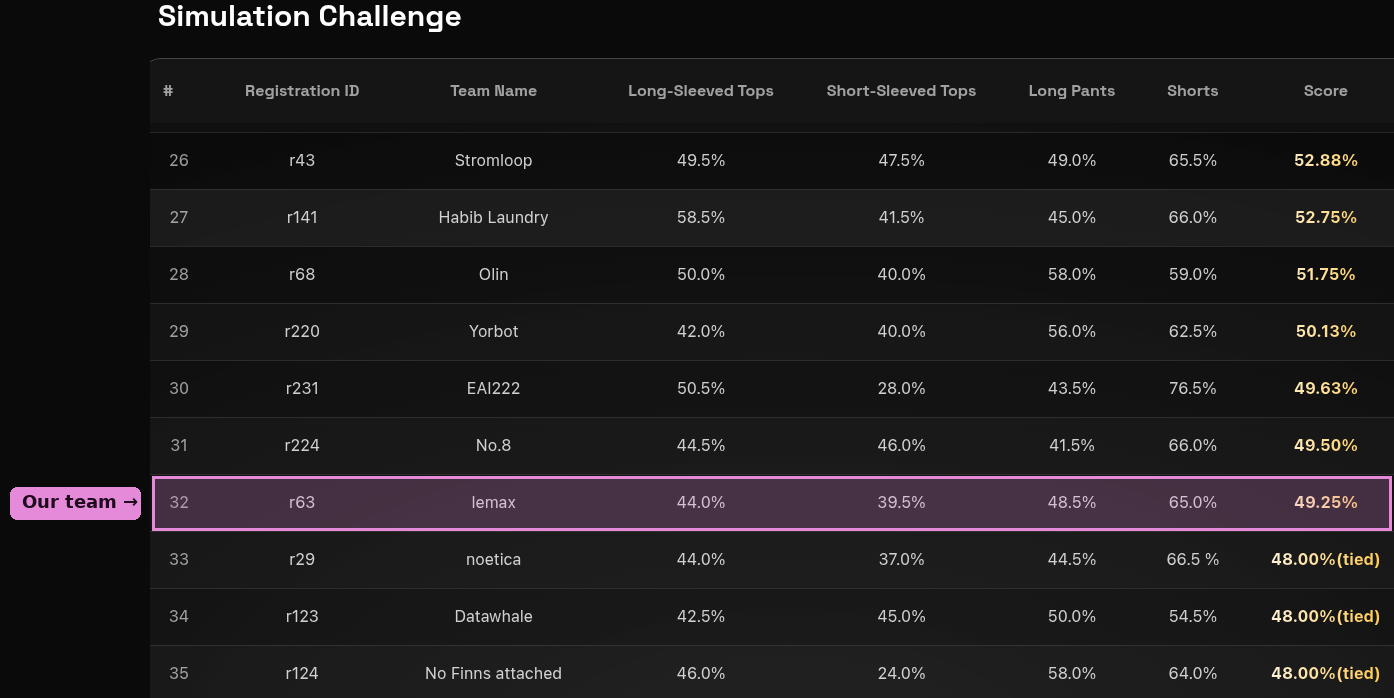
Rank 32 of 62, simulation round
LeHome Challenge, IEEE ICRA 2026
Bimanual garment folding in simulation, at the first deformable-manipulation challenge at ICRA.
- Learning
- Manipulation
- Perception
My contributions
- Compared four specialist SmolVLA policies, routed by a YOLO garment classifier, against one generalist policy.
- Reached 55% success locally and 49.25% on the final server evaluation, ranking 32 of 62 teams.
- Also evaluated ACT, X-VLA, diffusion policy and π0, including a SmolVLA and X-VLA hybrid.
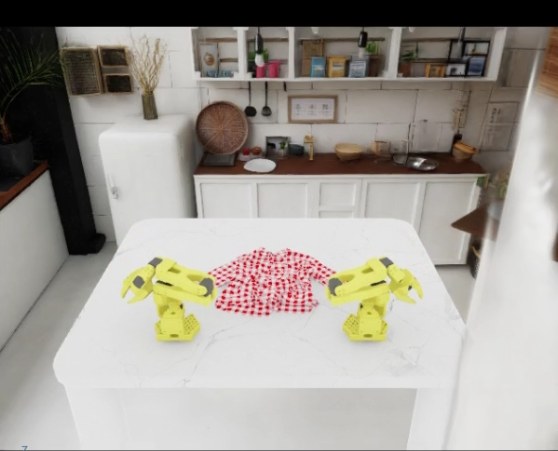
The LeHome Challenge at IEEE ICRA 2026 was the first simulation-driven competition on deformable object manipulation. Its task is garment folding in household scenes with a bimanual LeRobot SO-101 setup. The simulation round ran online from February to April 2026, and the top eight teams went on to a real-world round on site at ICRA in Vienna.
Each policy had to fold any of four garment categories, spawned at random: long-sleeved tops, short-sleeved tops, long pants and shorts.
Specialist or generalist
We compared four specialist SmolVLA policies, one per garment category and routed by a YOLO garment classifier, against a single generalist policy. Both reached about the same performance: 55% success locally and 49.25% on the final server evaluation.
We also evaluated ACT, X-VLA, diffusion policy and π0, including a SmolVLA and X-VLA hybrid for the specialist route.
Result
Our team, lemax, finished 32nd of 62 teams in the simulation round, with per-category success of 44.0% (long-sleeved tops), 39.5% (short-sleeved tops), 48.5% (long pants) and 65.0% (shorts).