Personal project
ROS 2 Differential-Drive Robot from Scratch
My first robot built from the ground up: wiring, power and motor control, driven over ROS 2.
- Hardware
My contributions
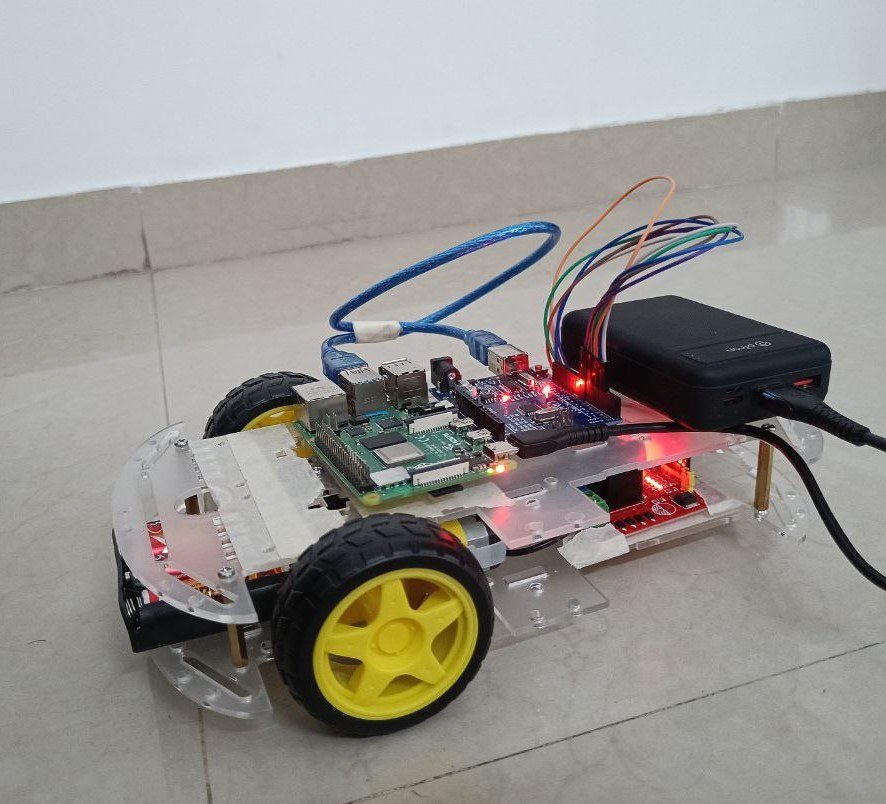
- Built a two-wheel differential-drive robot from scratch, through two hardware prototypes.
- Wired the power and motor electronics, and linked a Raspberry Pi 4 to an Arduino Uno over UART.
- Ran ROS 2 across a host PC and the Pi, with keyboard teleoperation driving the motors.
My first attempt at building a working robot on real hardware, from the chassis up. The software is deliberately simple, keyboard teleoperation; the point was to learn the electronics: power, motor drivers, wiring and getting a computer to talk to a microcontroller reliably.
Hardware
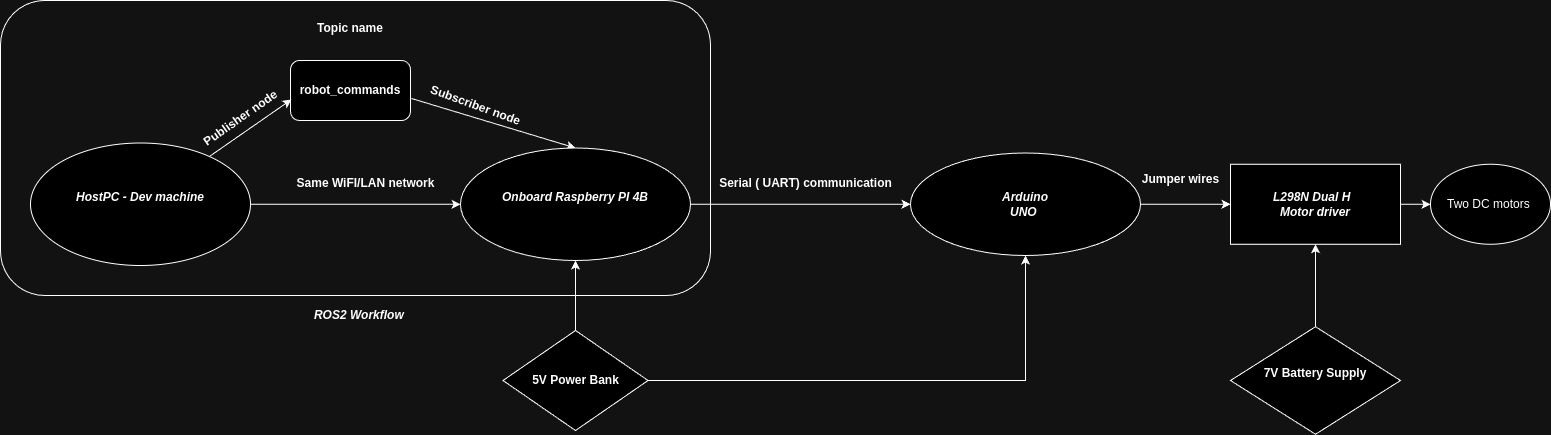
Two DC motors with rubber wheels and a castor, on a two-layer acrylic body. The first prototype drove the motors through an L298N driver from a separate 7 V supply, with a 12 V power bank for the electronics. The second swapped in an Arduino motor shield, which performed better and simplified the wiring.
How it talks
ROS 2 runs on both a host PC and an onboard Raspberry Pi 4 on the same network. A teleoperation node on the PC maps W, A, S and D to drive commands and publishes them on a topic. A node on the Pi subscribes and forwards each command over UART to an Arduino Uno, which sets the motor speeds and directions.
The robot was also modelled in URDF for simulation in Gazebo. Encoder feedback and a PID speed loop were the planned next step.
Gallery