Software and autonomy lead
NITK Autonomous Campus Shuttle
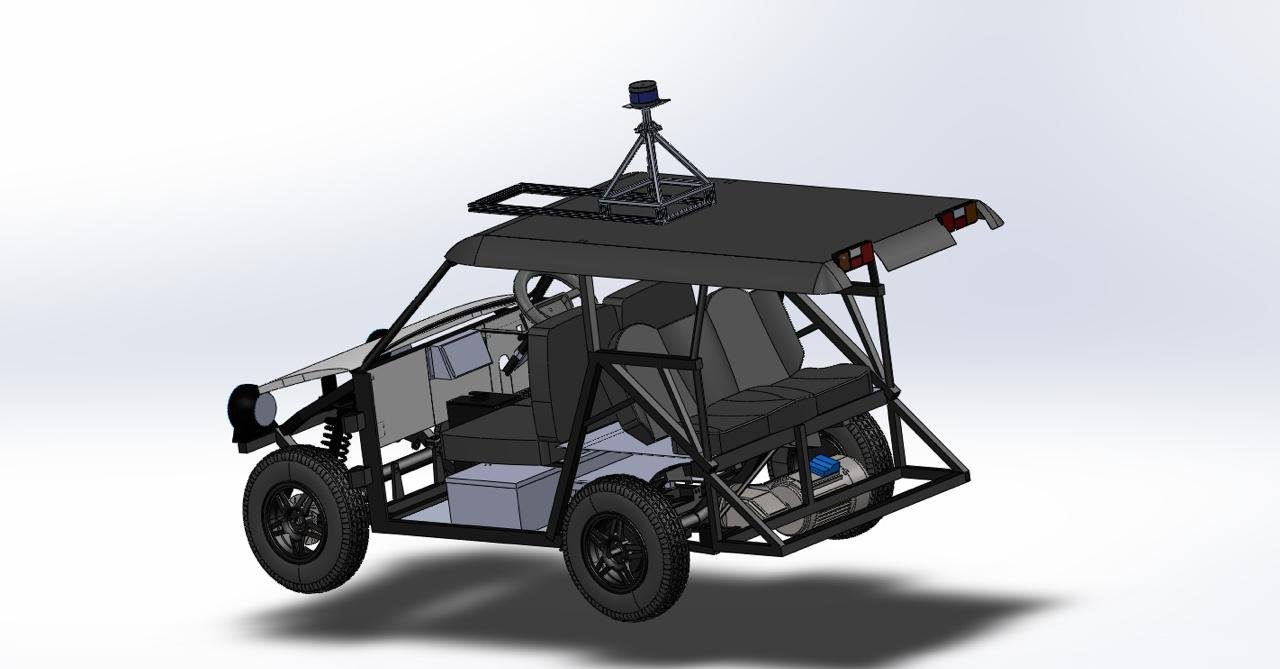
An L5 autonomous campus shuttle on a Mahindra Reva electric chassis, built on Autoware and ROS 2.
- Autonomous Driving
- SLAM
My contributions
- Guided the team on the software and algorithm side of an L5 shuttle on a Mahindra Reva electric chassis.
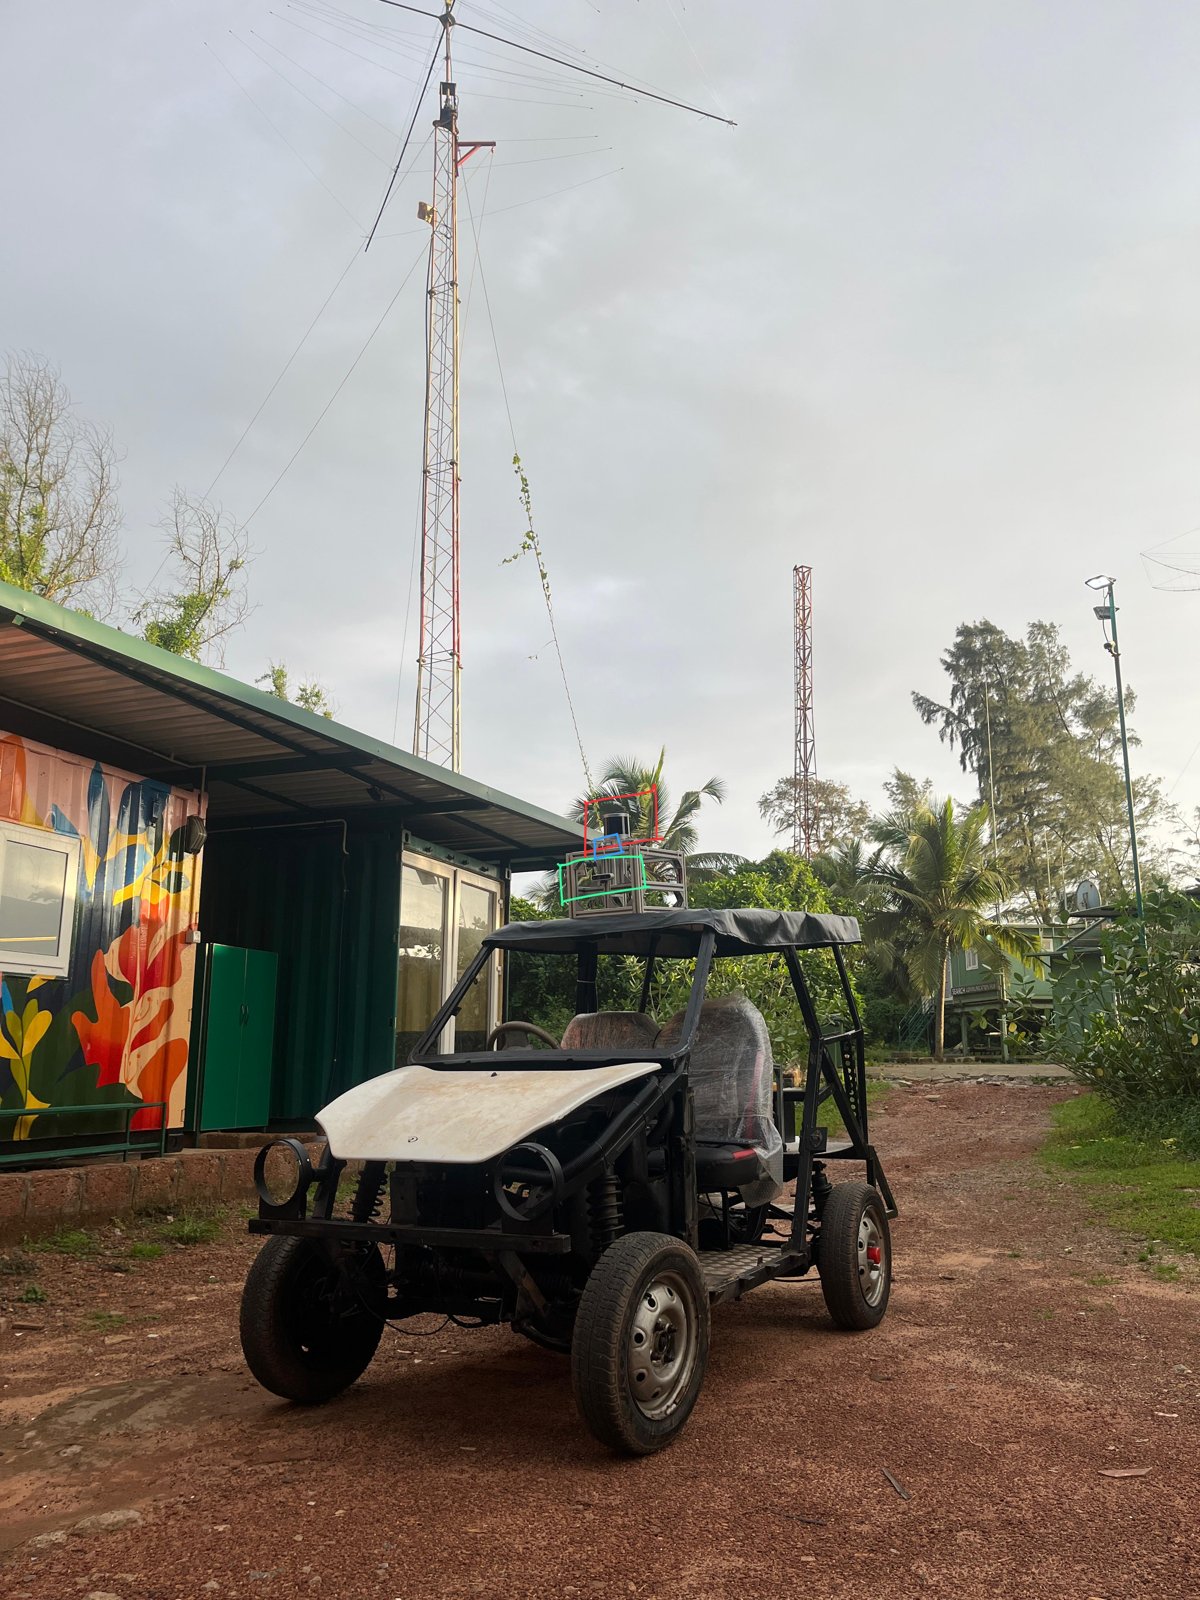
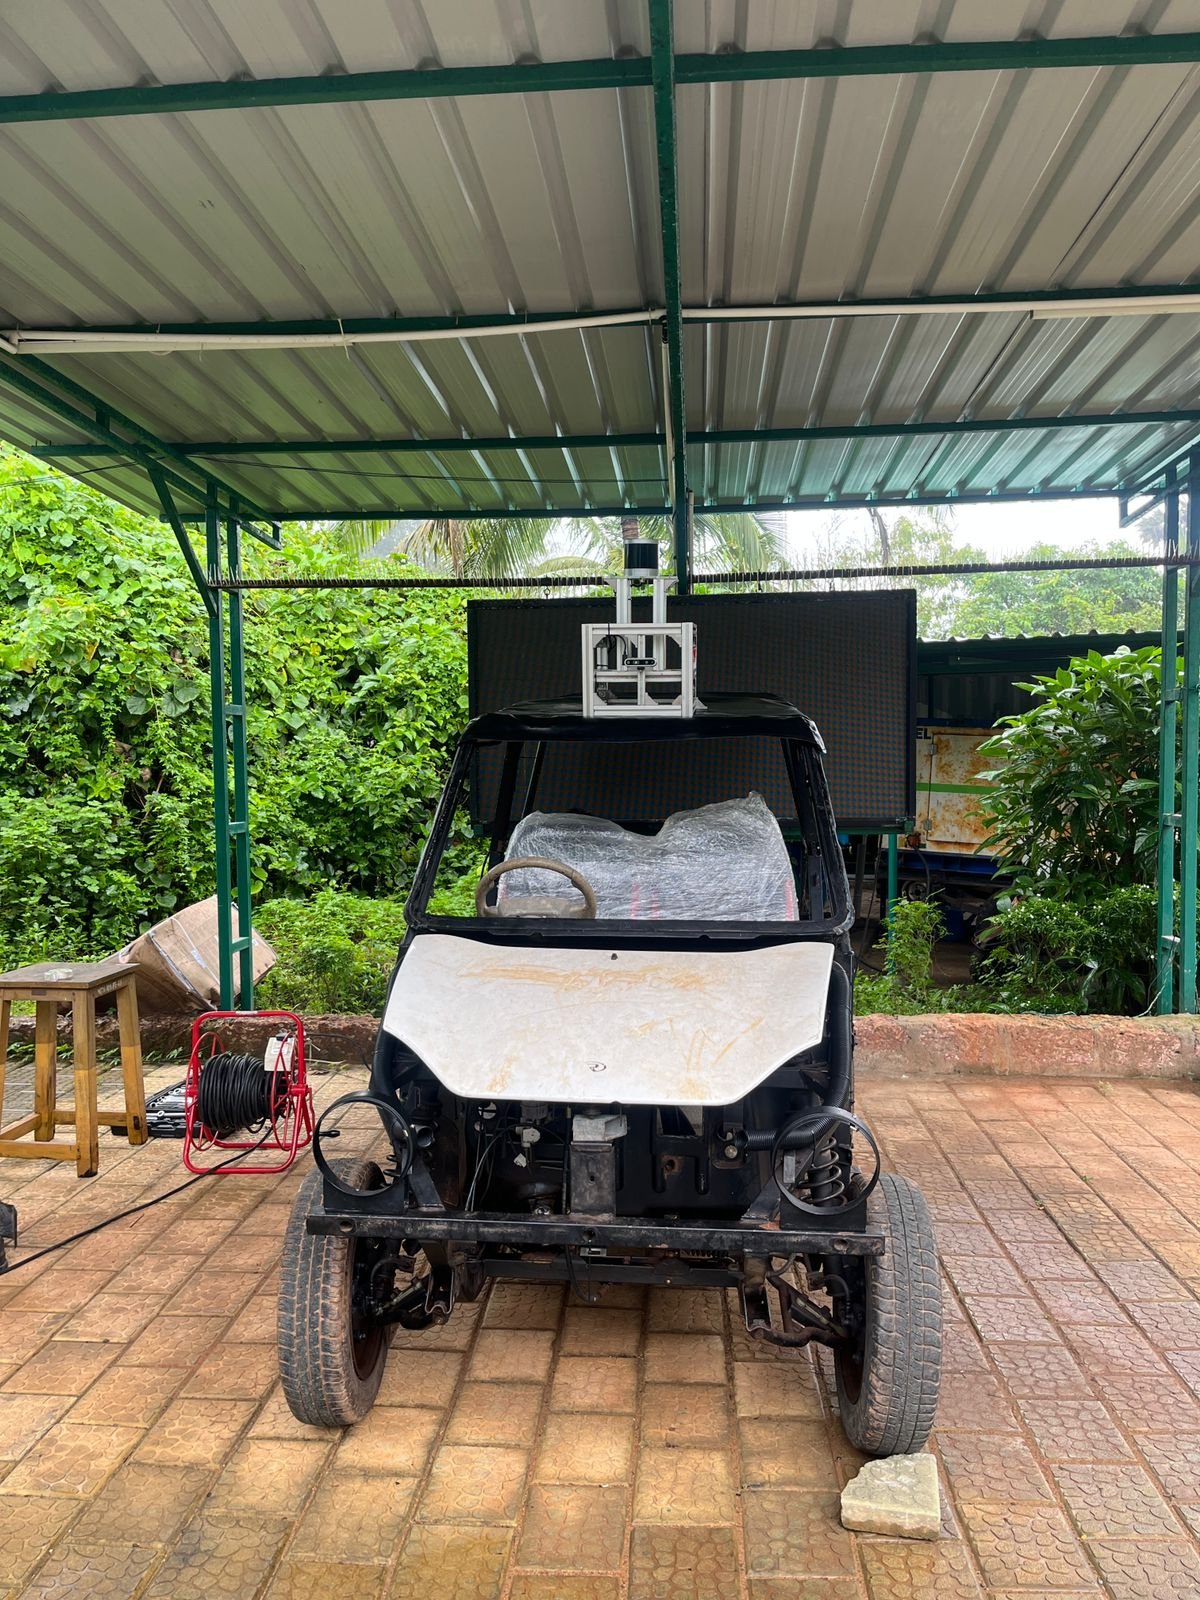
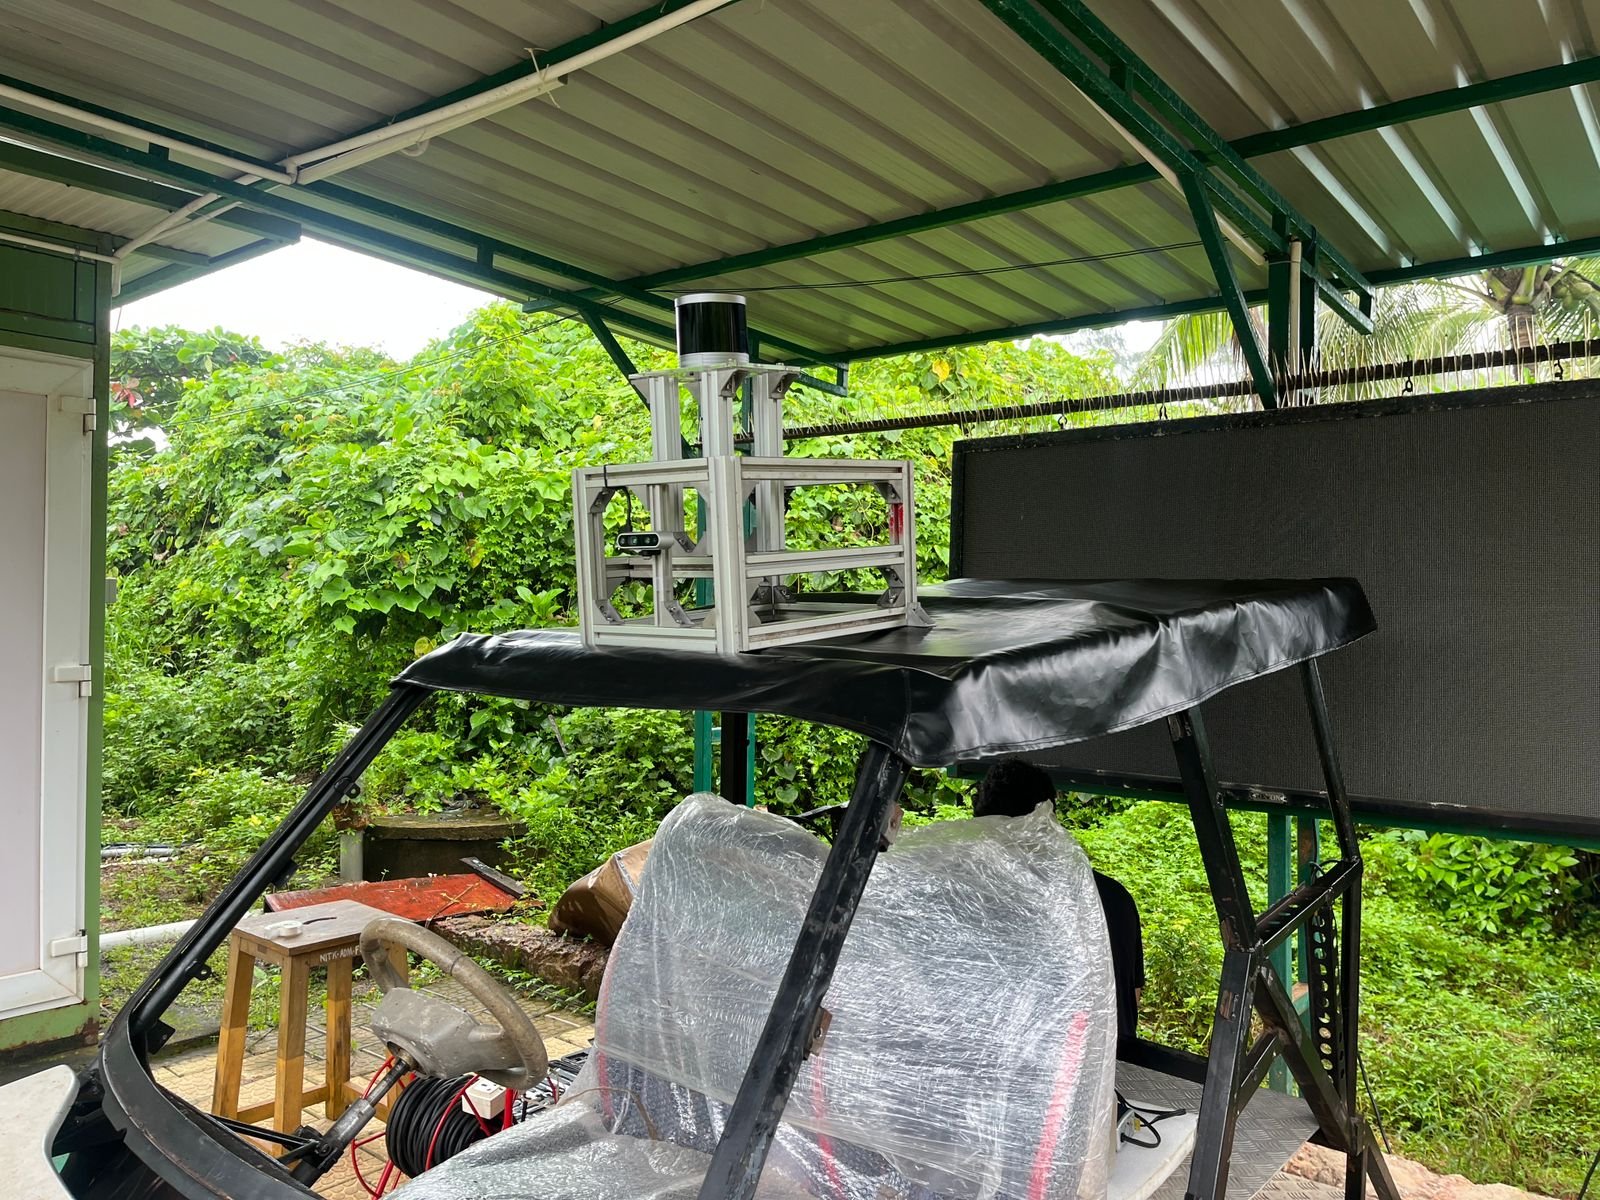
- Chose the sensor suite (Velodyne 3D LiDAR, RealSense D435i, 11-axis IMU + GNSS) and set up Autoware on ROS 2 as the core stack.
- Chose and integrated LIO-SAM, used to map a large part of the NITK campus before point-to-point autonomous runs.
An autonomous shuttle for the NITK campus, built at the Centre for System Design on a Mahindra Reva electric chassis. I guided the software and algorithms; the hardware, drive-by-wire conversion and field testing were done by Manish and the CSD team, who also built and ran everything shown here.
Sensors and stack
I chose the sensor suite: a Velodyne 3D LiDAR, an Intel RealSense D435i depth camera and an 11-axis IMU with GNSS that works with ROS 1 and ROS 2. The software is built on Autoware, with ROS 2 as middleware.
Mapping the campus
For localisation I chose LIO-SAM, a tightly coupled LiDAR-inertial SLAM system. It was used to build a 3D map of a large part of the campus, which the vehicle then localises against.
Autonomous runs
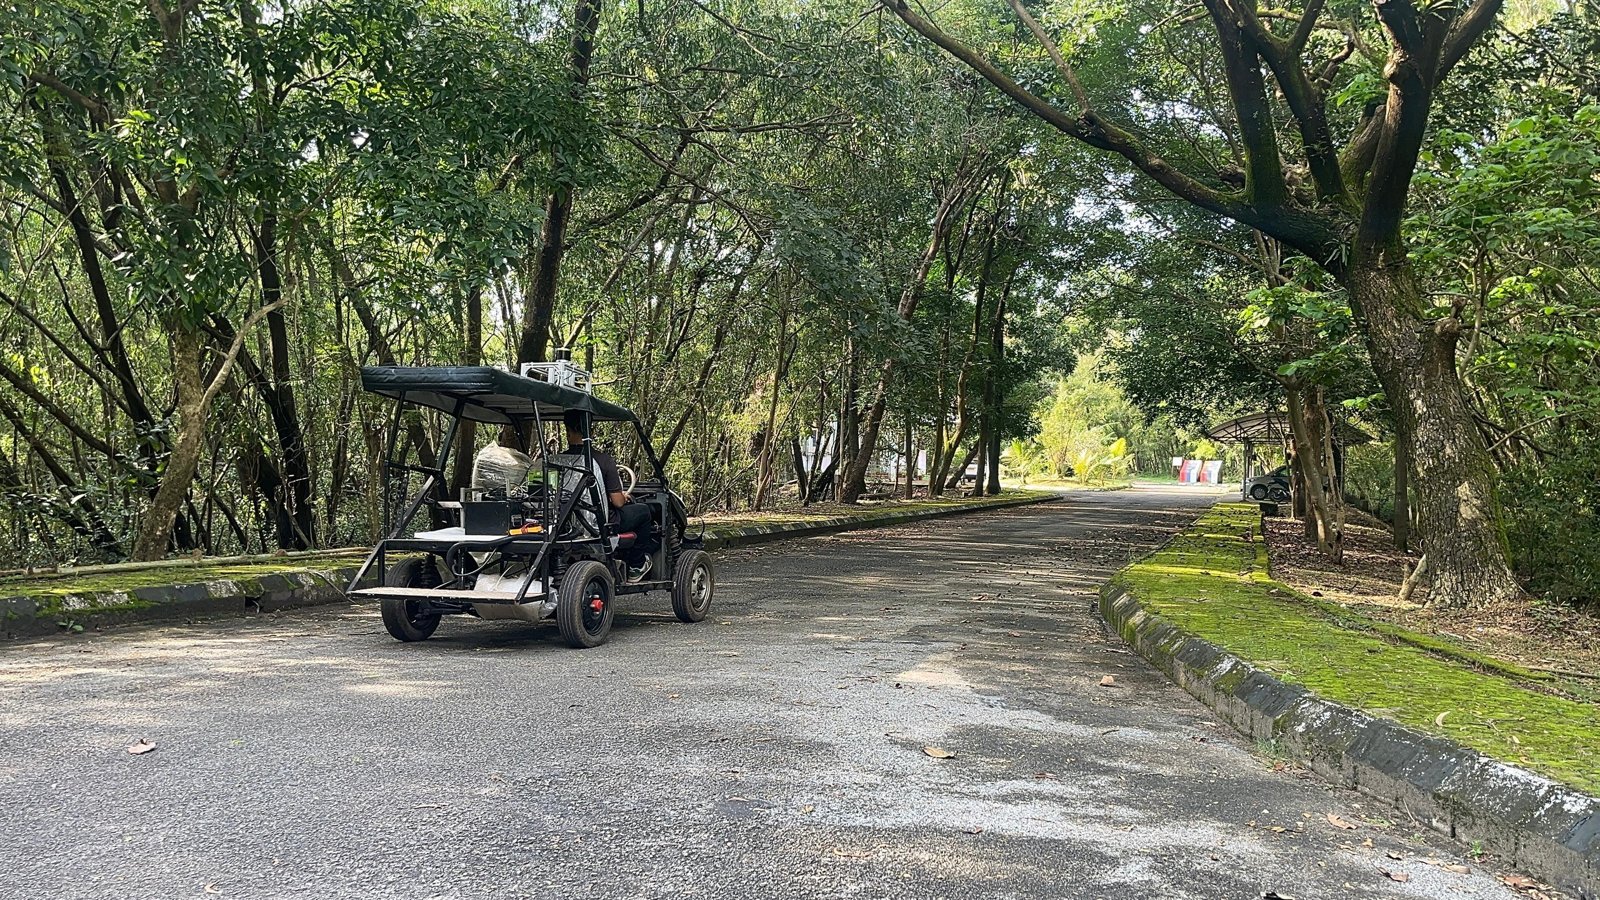
With the map in place, the shuttle drove point-to-point on campus roads under Autoware, including a run where it had to respond to a person walking into its path.
Gallery