eYSIP 2024, ARMS Lab
Autonomous Ackermann Vehicle for Field Exploration
A ROS 2 four-wheel-drive Ackermann vehicle, from motor control to autonomous navigation.
- Navigation
- SLAM
- State Estimation
- Hardware
My contributions
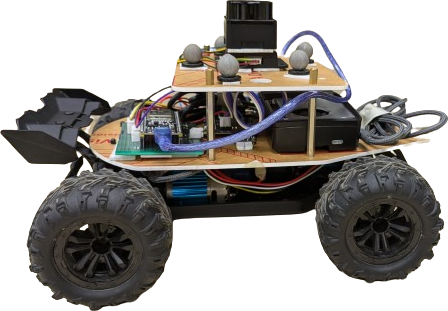
- Built a ROS 2 4WD Ackermann vehicle, from motor and steering control to autonomous navigation.
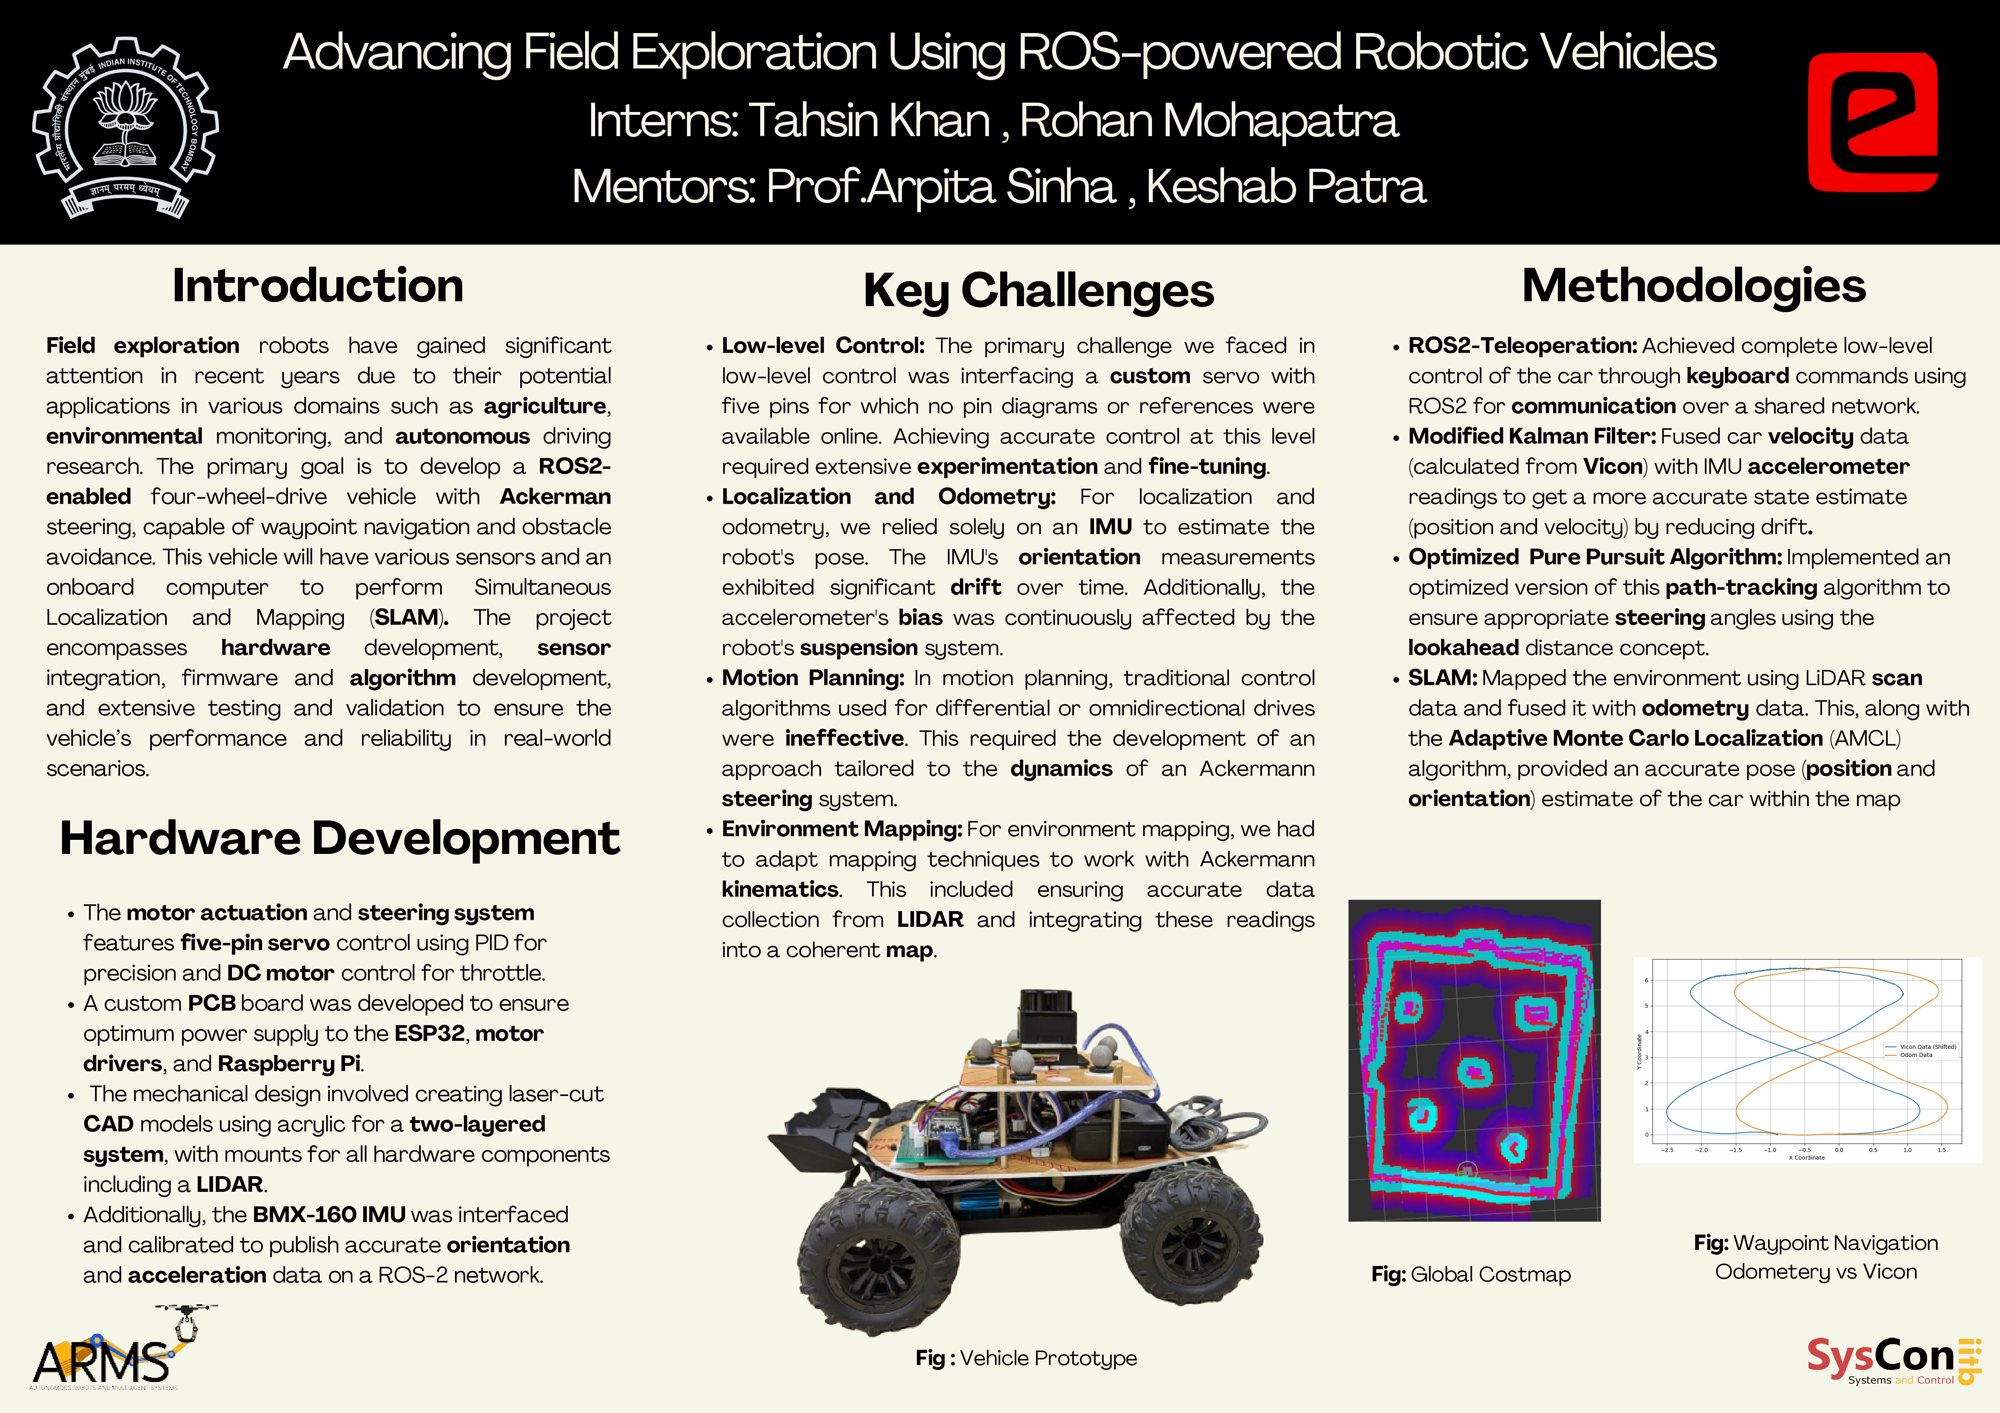
- Fused the IMU with Vicon velocity estimates in a Kalman filter for odometry.
- Ran LiDAR SLAM with AMCL localisation in Nav2 and a pure-pursuit planner for waypoints.
At the Autonomous Robots and Multi-Systems (ARMS) Lab, IIT Bombay, I built a ROS 2-controlled four-wheel-drive Ackermann vehicle for field exploration, taking it from low-level motor and steering control through to autonomous navigation on the physical platform.
State estimation
Odometry fuses the IMU with Vicon velocity estimates through a Kalman filter.
Mapping, localisation and planning
LiDAR SLAM builds the map, AMCL in Nav2 localises the vehicle in it, and a pure-pursuit planner drives it through waypoints.
Gallery